

SOMA-X Documentation#
SOMA-X provides canonical full-body and wrist-local hand layers, model interoperability, pose inversion, and shared geometry utilities. Start with the installation and tools guides, then use the model and API references for the exact runtime contracts.
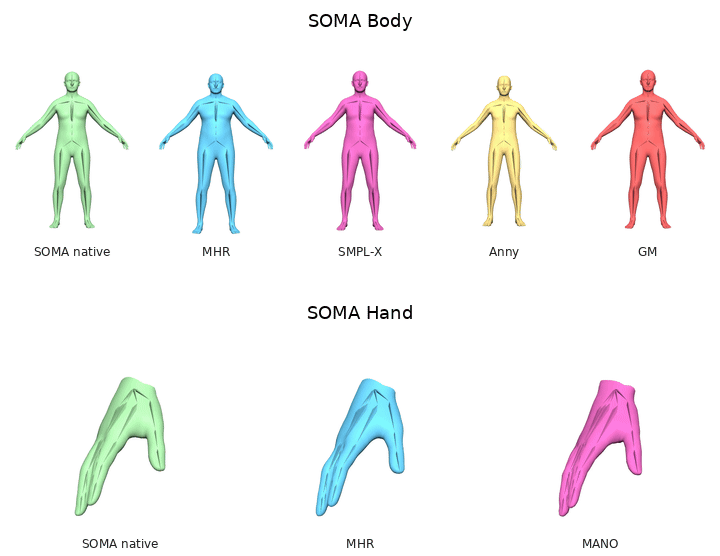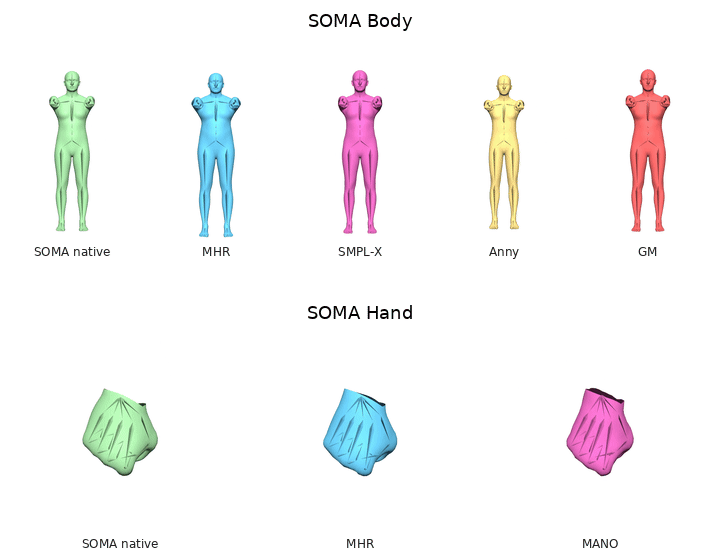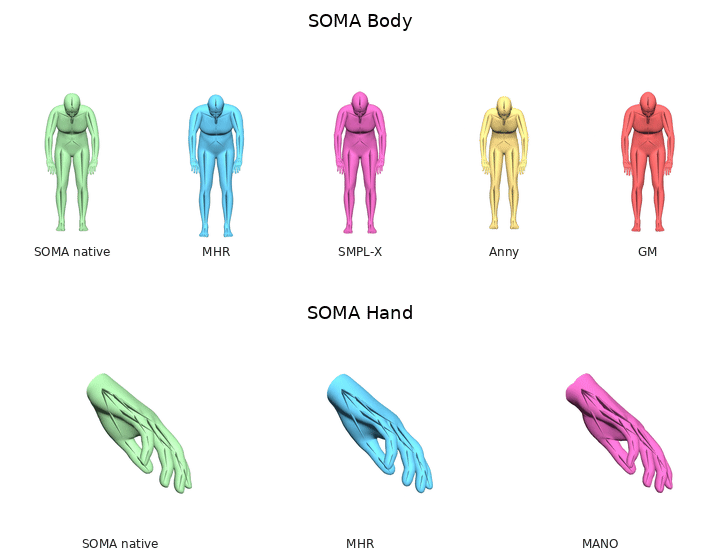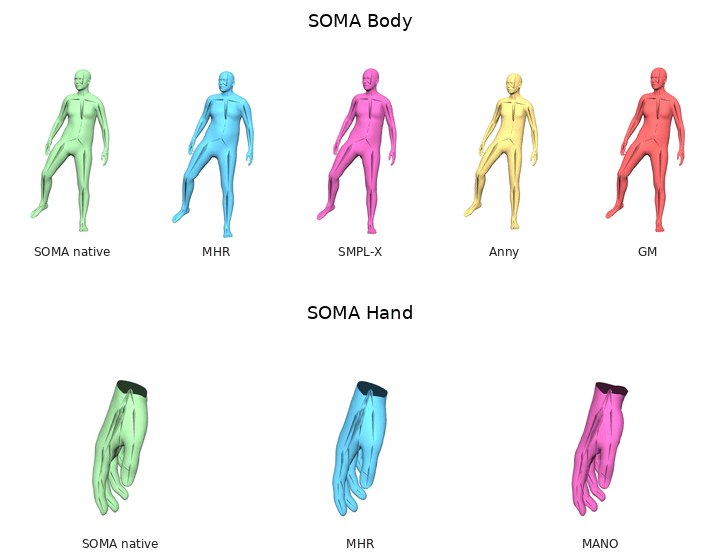
All identity models below are driven by SOMA’s unified body and hand skeletons.
Local preview#
Install the docs dependencies:
uv pip install -e ".[docs]"
Build and serve locally:
SOMA_DOCS_AUDIENCE=public DOC_VERSION=0.3 sphinx-build -b html docs docs/_build/html
python -m http.server -d docs/_build/html
Then open http://127.0.0.1:8000/.